


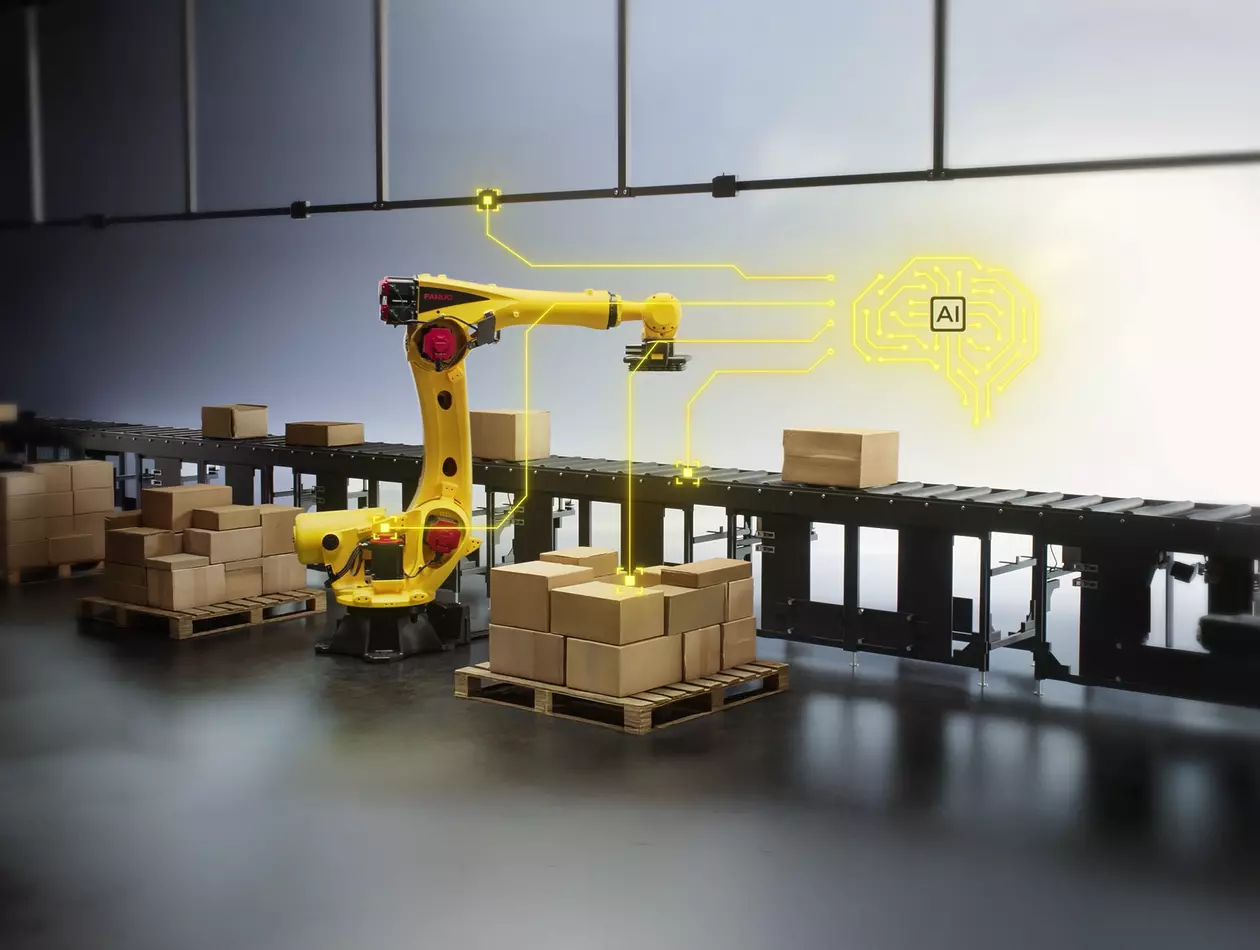
Driver FANUC ROS 2 para integração de robôs industriais
Integrate FANUC Robots with ROS 2 Driver
FANUC has released its ROS 2 driver for the CRX collaborative robot series, enabling seamless integration with the Robot Operating System 2 (ROS 2). This gives developers, researchers, and manufacturers greater flexibility to create intelligent robotic applications using a modern, scalable framework designed for real-time robot control and advanced automation.
What is the FANUC ROS 2 Driver?
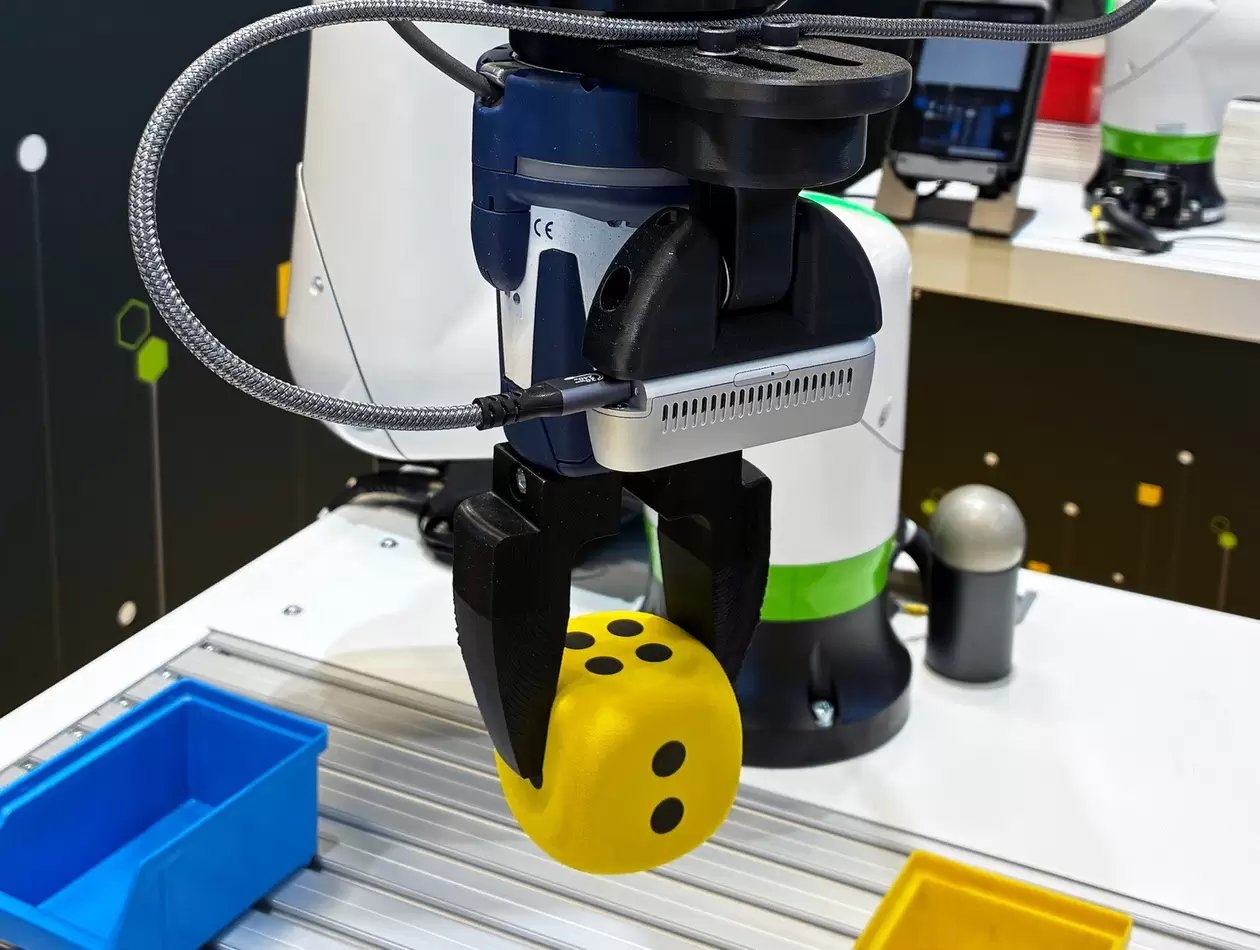
The FANUC ROS 2 driver is a software interface that connects FANUC CRX Collaborative Robots to the ROS 2 ecosystem. It empowers users to leverage open-source tools for advanced automation, research, and industrial deployment. The driver supports high-frequency control, MoveIt integration, and simulation capabilities, enabling flexible deployment across research and production environments.
Get Started with the FANUC ROS 2 Driver
The FANUC ROS 2 driver is available now for the CRX Collaborative Robot Series and several other models. Developers can access documentation, installation guides, and support via FANUC CORPORATION’s official GitHub repositories.
Aplicações de IA física — Promover a IA física através da integração aberta com o ROS
Controlo de movimento em tempo real e de alta frequência
Planeamento avançado de movimentos e prevenção de colisões
Simulação e prototipagem virtual
Integração flexível
Amplo suporte a modelos
Fiabilidade de nível industrial
*ROS é uma marca comercial da Open Source Robotics Foundation.
**Python é uma marca registada da Python Software Foundation.
***GitHub é uma marca registada da GitHub, Inc.